Application Note / 2026-09-06
Gripper Finger Wear Inspection Record for CNC Machine Tending
An inspection record keeps the actual finger and contact surface traceable, separates observations from evidence, and preserves an authorized follow-up without estimating life.
 Application scenario illustration
A CNC machine tending gripper finger wear inspection record should identify the actual gripper, finger or tip, side, available revision, contact geometry or material, workpiece and inspected surface. It should point to the correct model instruction and the authorized inspection state actually used, then keep visible condition, motion, grip confirmation, part-present evidence and workpiece marks as separate observations. A disposition needs evidence, date, reviewer, owner and follow-up. The record does not create a universal wear limit, replacement interval or remaining-life estimate.
Start with the finger that is actually installed
“The gripper” is too broad for an auditable inspection. Record the installed gripper, the finger and fingertip or contact insert, any available revision, the left or right side, the contact geometry or material, the workpiece and the specific inspected surface. Those fields make it possible to distinguish a finger from a similar-looking replacement or a contact surface from a non-contact face.
The inspection context should stay tied to the installed application. CNC loading gripper design inputs provides the broader gripper context; this record stays with the actual fingers and workpiece-contact surfaces in service.
Use the correct model instruction for the inspection state
The inspection record should point to the selected manufacturer and model instruction, then capture the authorized inspection state actually used. A generic article cannot prescribe a single method for power isolation, disassembly, manual movement or maintenance access because the selected equipment and site procedure determine those requirements.
This distinction matters when a finger is connected to a broader end-of-arm assembly. The quick-change EOAT interface record covers master-to-tool identity and change linkage.
 Application scenario illustration
Record observations that can be located and evidenced
Objective inspection entries may cover motion symmetry or fluidity, return behavior, visible fingertip or chassis wear, collision damage, debris or contamination, and the exact left or right location. Tie photographs or measurements to the date and inspection setup so the record can later be read alongside the relevant instruction.
Do not turn a visible mark into a universal reject decision. Manufacturer examples may describe their own product observations, but acceptance criteria belong to the installed tool's documentation and the authorized project decision. This page does not define a wear depth, clearance, force, motion or contamination limit.
Keep condition, motion and evidence from sensors separate
Visible condition, motion behavior, gripping confirmation, part-present evidence and workpiece marks answer different questions. One actuator position or signal does not prove that the intended part is held correctly, and a workpiece mark alone does not establish the source of a condition.
For the separate subject of evidence that a part is present, use the part-present sensing record. If the complete moving wrist assembly changes, the six-axis robot payload record is likewise a separate record.
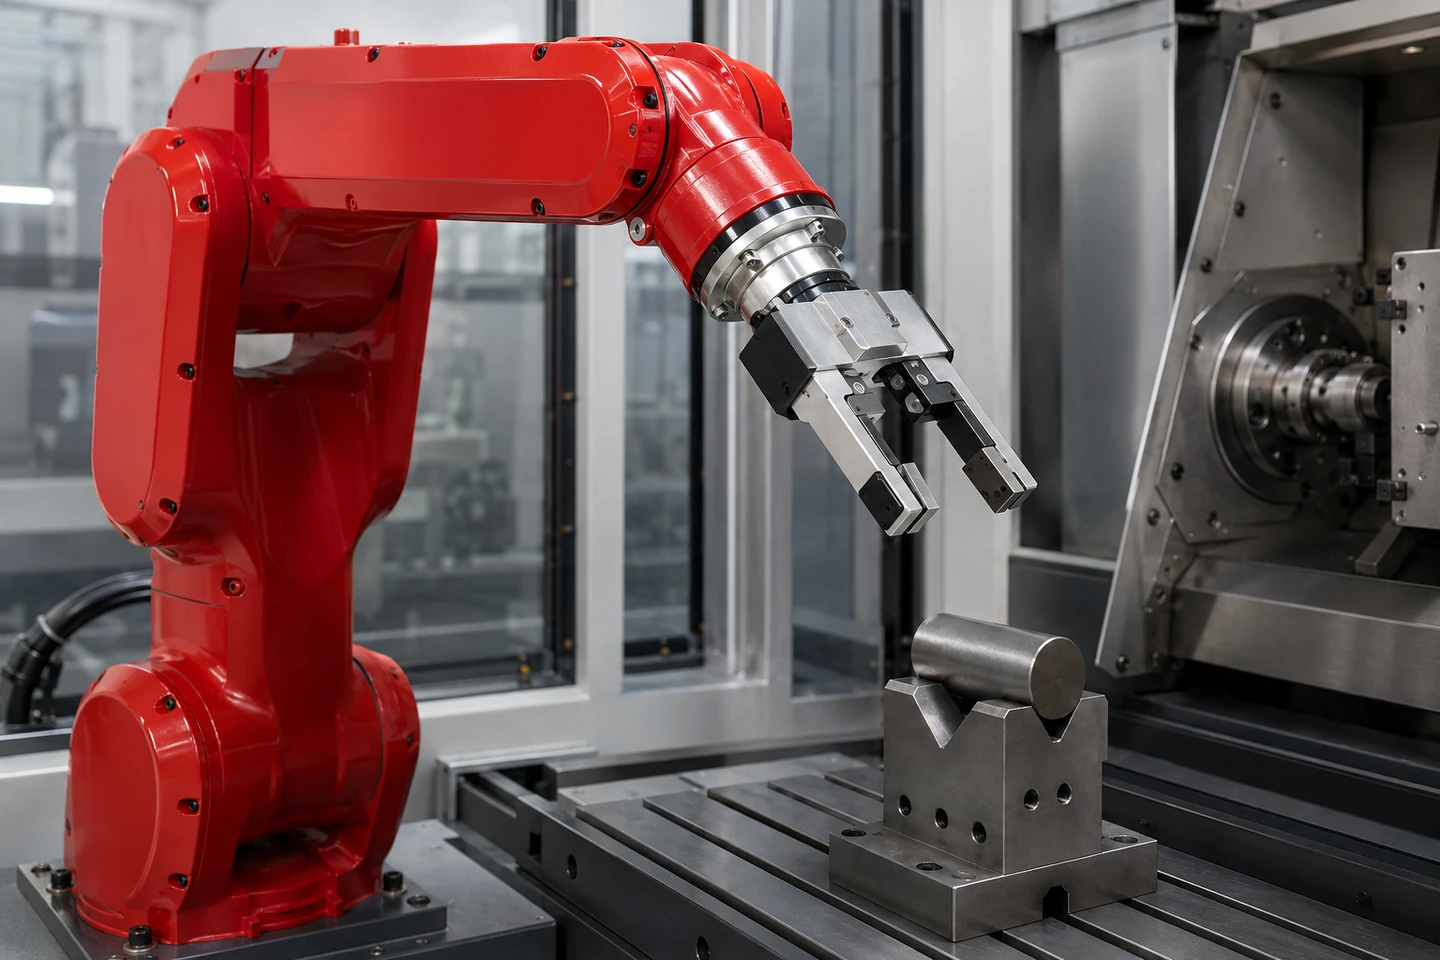 Application scenario illustration
Preserve the authorized disposition and follow-up
An inspection record becomes traceable when the disposition is an authorized decision, with its reviewer, evidence, date, owner and next action retained. If a finger or tip changes, preserve the removed and installed item identities and the required follow-up verification. Do not infer remaining life, warranty status or a replacement interval from one observation.
The high-mix changeover checklist is useful where an application changes between part families. Selection, quality, safety and production decisions remain project-specific.
Fillable gripper finger wear inspection record
| Installed item and inspection context | Objective observation and exact location | Manual reference, date and evidence | Authorized disposition, owner and follow-up |
|---|---|---|---|
| Gripper, finger and tip identity | Enter observed item | Enter correct manual and evidence | Enter authorized follow-up |
| Left or right contact surface | Enter visible condition | Enter dated evidence | Enter authorized follow-up |
| Motion symmetry or fluidity | Enter observation | Enter dated evidence | Enter authorized follow-up |
| Return behavior | Enter observation | Enter dated evidence | Enter authorized follow-up |
| Visible wear or damage | Enter exact location | Enter dated evidence | Enter authorized follow-up |
| Debris or contamination | Enter exact location | Enter dated evidence | Enter authorized follow-up |
| Grip confirmation and part-present evidence | Enter separately | Enter evidence source | Enter authorized follow-up |
| Workpiece marks or changed part | Enter separately | Enter dated evidence | Enter authorized follow-up |
For the overall one-machine context, see the single-machine CNC tending solution.
Frequently asked questions
Can visible wear alone be a universal reject criterion?
No. Record the visible condition and its exact location, then use the installed tool's criteria and an authorized decision. This article provides no universal limit.
Does actuator position prove the intended part is held correctly?
No. Position, grip confirmation and part-present evidence need separate records. A single signal cannot establish every condition of the intended grip.
Can this page prescribe one isolation or disassembly method?
No. Follow the correct manufacturer and model documentation together with the site procedure. The article does not provide an isolation, disassembly, repair or manual-movement method.
Can the record estimate remaining life or warranty?
No. It preserves observations and an authorized follow-up. Remaining life, warranty and replacement decisions cannot be inferred from this record.
Sources and use boundary
- Robotiq 2F-85 & 2F-140 Instruction Manual: a model-specific example for recording visible condition, motion and return observations; it does not set a universal inspection method or limit.
- QIXING CNC loading gripper design: context for workpiece geometry, contact surfaces and contamination.
- HSE maintenance of work equipment: general guidance on records, competent personnel and manufacturer instructions; it is not a global compliance finding.
Use the installed tool's correct documentation and the authorized site procedure for inspection and disposition. This record does not set a wear limit, replacement interval, remaining-life estimate, repair method, safety conclusion or production release.
Send inspection inputs for structured review
For a structured QIXING discussion, gather the actual gripper, finger or tip identity, available revision, side, workpiece and contact surface, correct manual reference, dated photos or measurements, observed condition and open disposition, then send inspection inputs. Do not send credentials or sensitive support files.